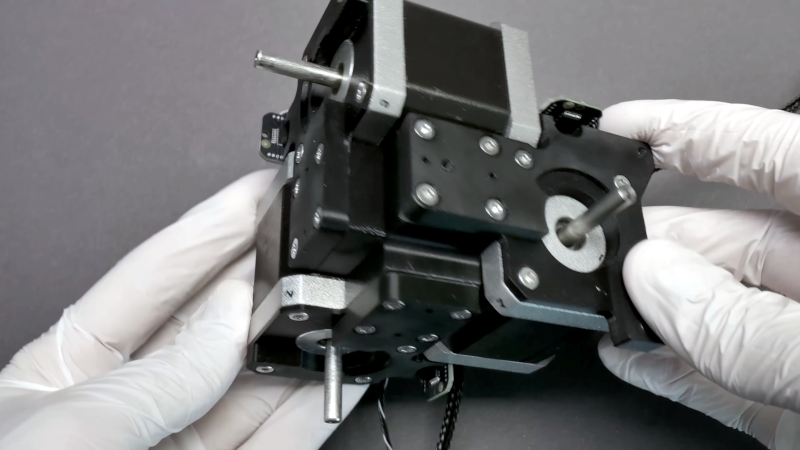
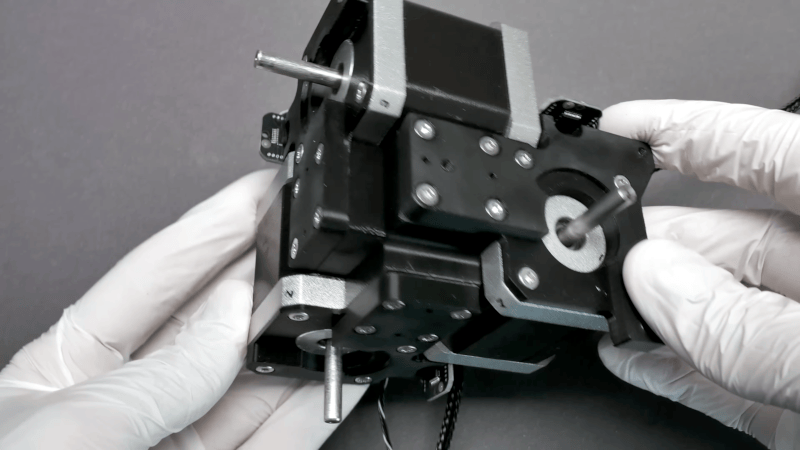
If you need a micro-manipulator, you probably already have a good idea of what it does. For example, you might be moving a probe over an IC die or wafer. You might be looking at something through a microscope. The key is moving something in very small, precise increments along three axes. An open-source design for a micro-manipulator has seen significant improvements lately. You can see several videos about the device below.
The device uses stepper motors, parallel kinematics, and miniature ball joints to achieve precise motion. The recent version 4.0 update fixes a few problems. According to the GitHub page:
- Self-collision during homing fixed.
- Connection of the ball joint block with screws only was not well constrained and could be rotated a bit.
- No reliable way to ensure consistent linkage rod length
- Unnecessary ball joint friction
- Accurate ball position heavily dependent on print quality and corner rounding
- Rubber bands could not be changed or removed once glued in.
We’ve covered earlier versions of this device, and we were watching the improvements to the ball joints. Since then, the project has updated much of its mechanical design and documentation, and it has also changed the API that drives it. It can even use tools in g-code now to support things like fine control over laser engraving.
If you prefer something old-school manual, consider a 3D-printed one.
This articles is written by : Fady Askharoun Samy Askharoun
All Rights Reserved to Amznusa www.amznusa.com
Why Amznusa?
AMZNUSA is a dynamic website that focuses on three primary categories: Technology, e-commerce and cryptocurrency news. It provides users with the latest updates and insights into online retail trends and the rapidly evolving world of digital currencies, helping visitors stay informed about both markets.
